

1000:1 Micro Metal Gearmotor HP 6V
SKU: 1595
MANUFACTURER: Pololu
SGD $75.00
Availability: 2
 |
| 1000:1 Micro Metal Gearmotor. |
|---|
Gearmotor details:
| motor/brush type | gearbox | encoder | |
|---|---|---|---|
| HP 6V: high-power 6V with precious metal brushes | 986.41:1 with brass plates | no encoder | |
Key specifications:
| voltage | no-load performance | stall extrapolation* |
|---|---|---|
| 6 V | 31 RPM, 100 mA | 12 kg⋅cm (166 oz⋅in), 1.6 A |
| * Note: Stall torque and stall current specifications are theoretical values; stalls could damage the motor or gearbox. | ||
Exact gear ratio: 25×34×35×34×34×34×2712×9×12×14×14×14×9≈986.41:1
Motor Accessories
- Wheels and hubs: The Micro Metal Gearmotor’s output shaft matches our assortment of Pololu wheels for 3mm shafts. You can also use our Pololu universal mounting hubs to mount custom wheels and mechanism to the Micro Metal Gearmotor’s output shaft, and you can use our 12mm hex wheel adapter to use this motor with many common hobby RC wheels.
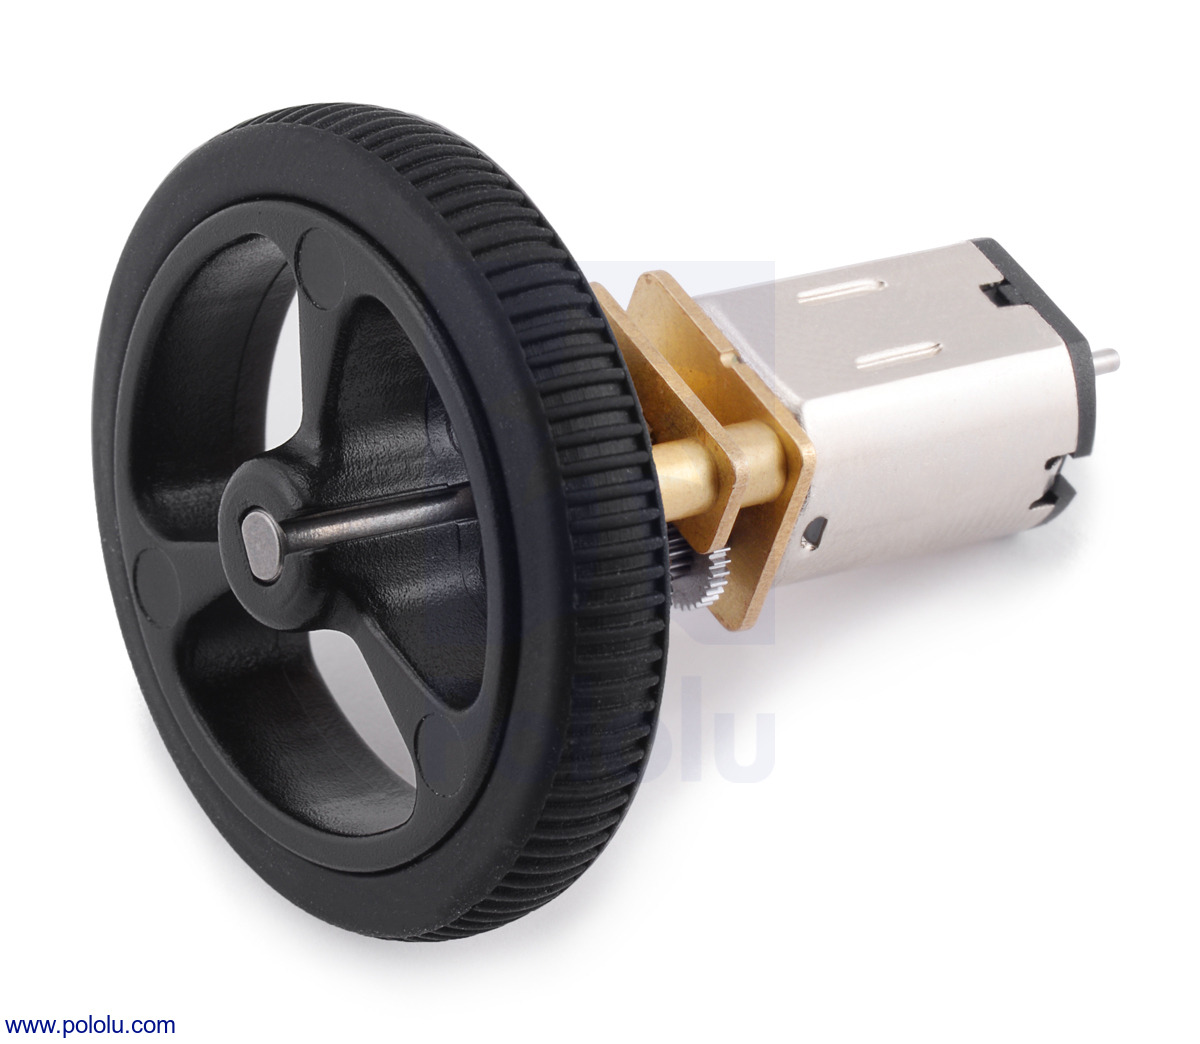 |
| Pololu Wheel 32×7mm on a Micro Metal Gearmotor. |
|---|
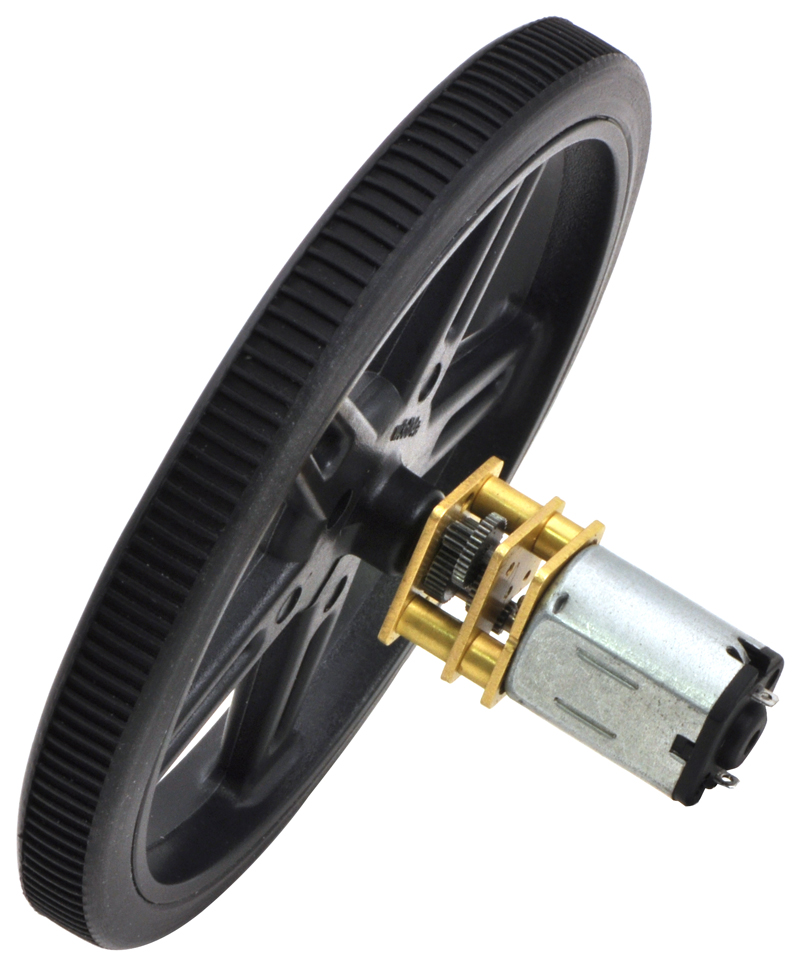 |
| Black Pololu Wheel 70×8mm on a Pololu Micro Metal Gearmotor. |
|---|
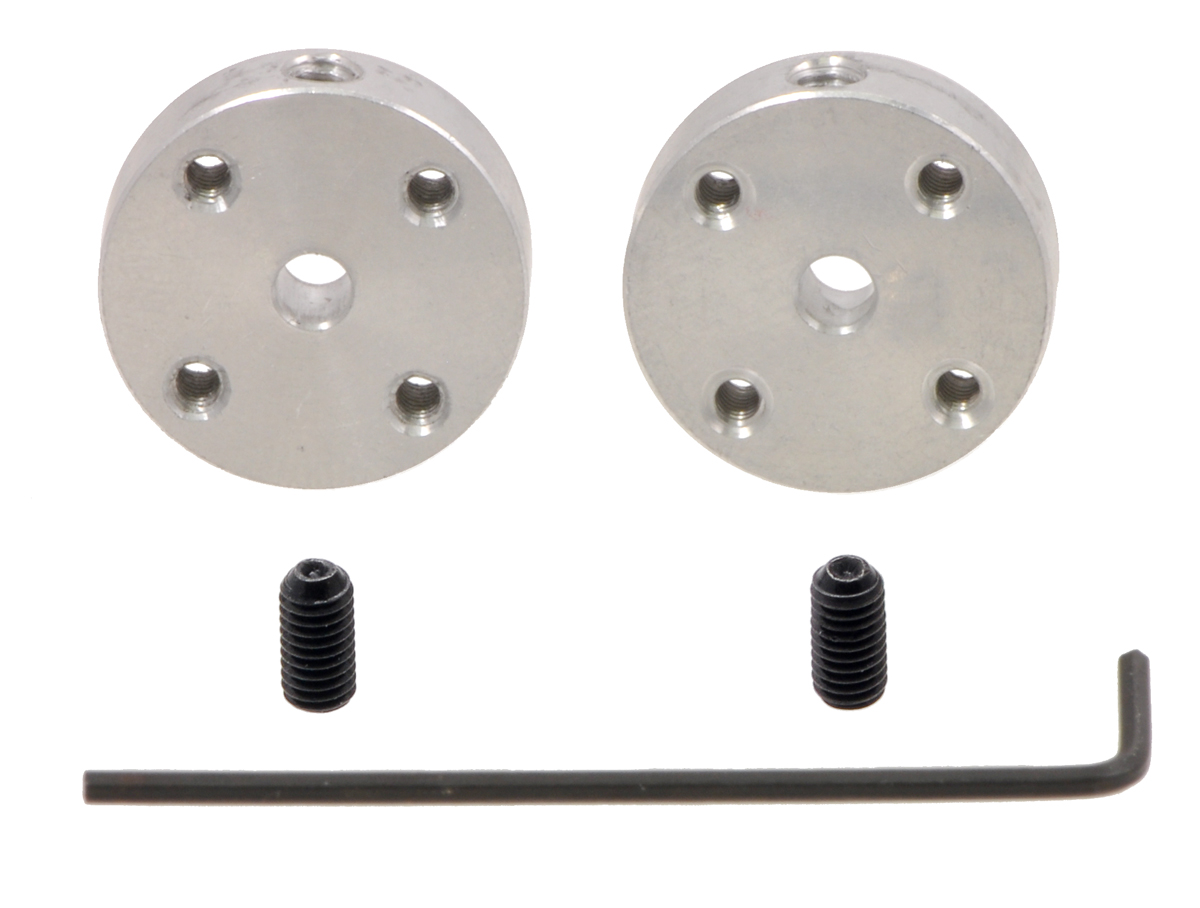 |
| A pair of Pololu universal aluminum mounting hubs for 3 mm diameter shafts. |
|---|
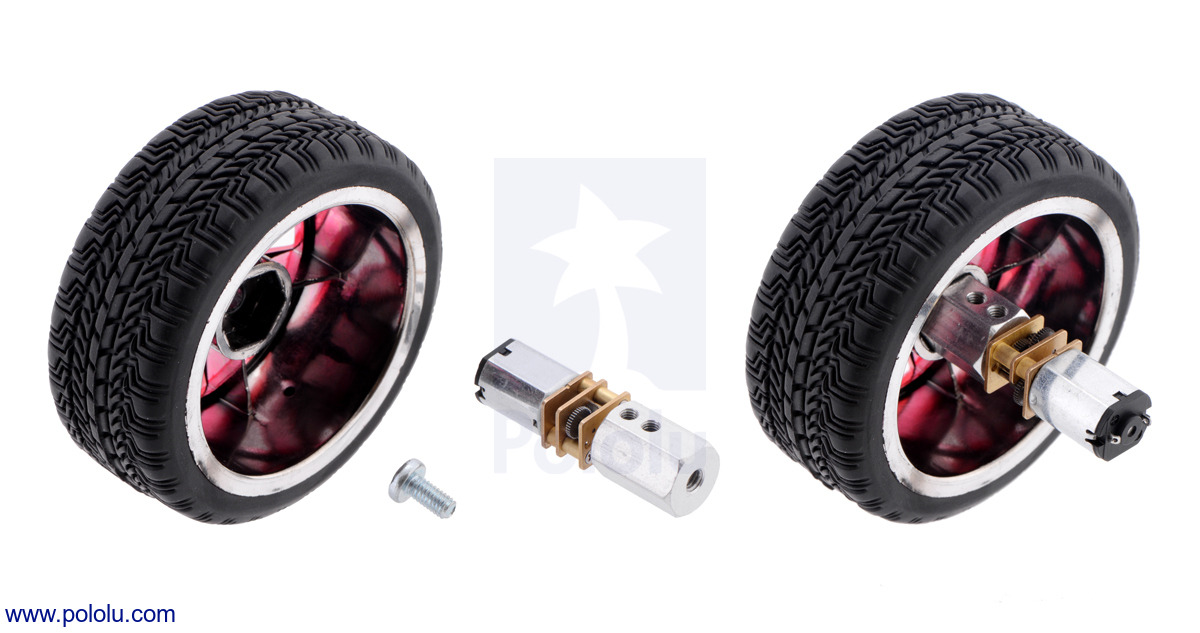 |
| 12mm Hex Wheel Adapter for 3mm Shaft on a Micro Metal Gearmotor. |
|---|
- Mounting brackets: Our mounting bracket (also available in white) and extended mounting bracket are specifically designed to securely mount the gearmotor while enclosing the exposed gears. We recommend the extended mounting bracket for wheels with recessed hubs, such as the Pololu wheel 42×19mm.
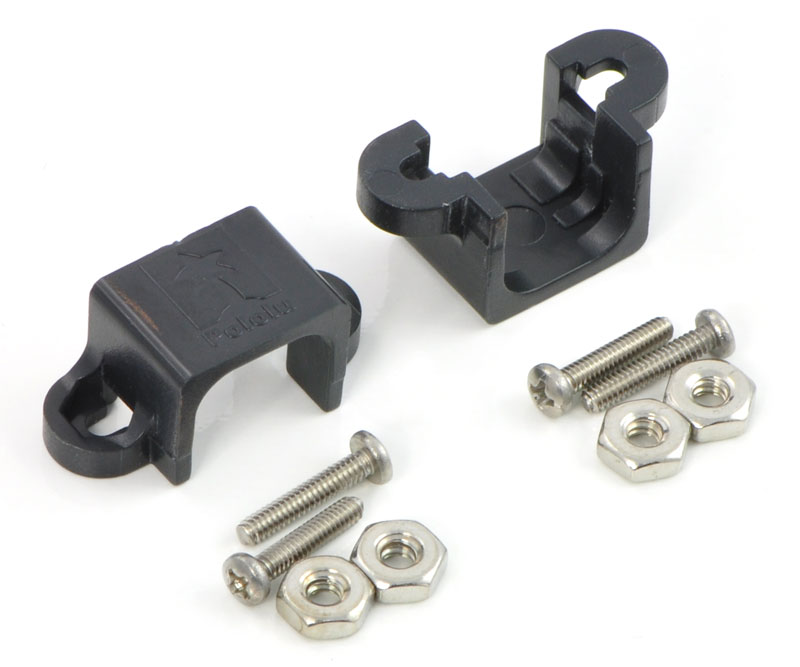 |
| Black micro metal gearmotor mounting bracket pair with included screws and nuts. |
|---|
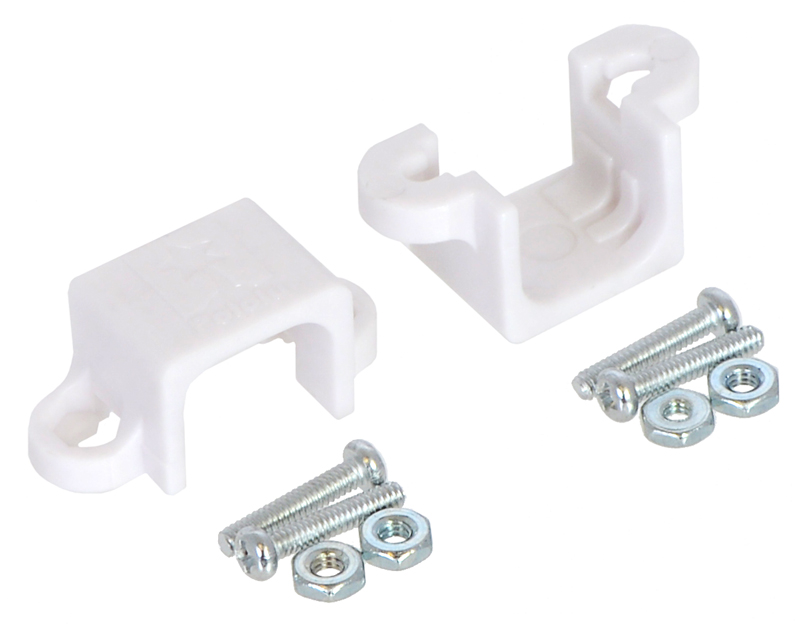 |
| White micro metal gearmotor mounting bracket pair with included screws and nuts. |
|---|
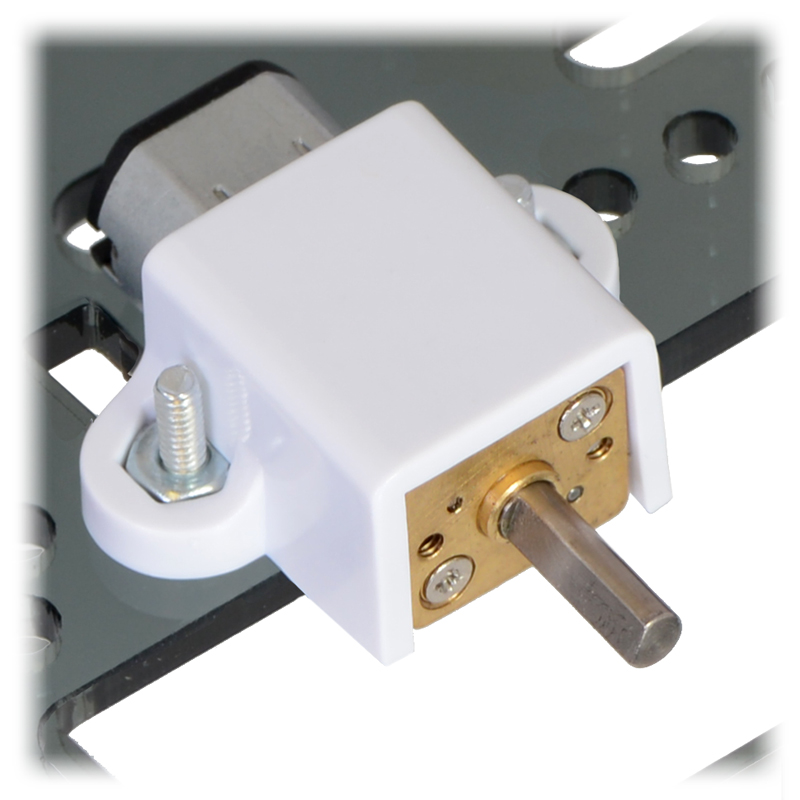 |
| Pololu micro metal gearmotor bracket extended with Micro Metal Gearmotor. |
|---|
- Encoders and connector boards: While we have versions of our Micro Metal Gearmotors available with encoders already installed, we also have encoder boards available separately that can be installed on the Micro Metal Gearmotor versions with extended motor shafts. For the single-shaft versions, we have 2-pin connector boards available that work with 2-pin JST SH-style female cables.
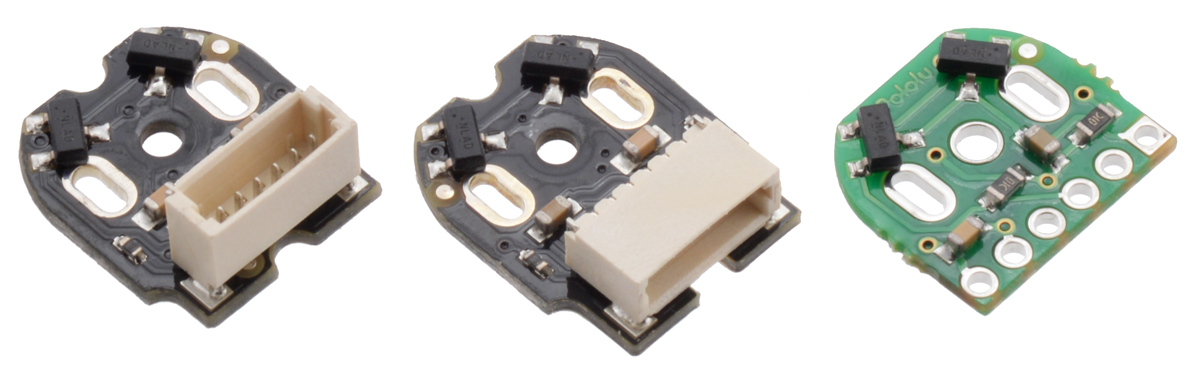 |
| Side-by-side comparison of Magnetic Encoder with Top-Entry Connector (left), Side-Entry Connector (center), and 2mm-pitch through-holes (right). |
|---|
 |
| Micro Metal Gearmotor with Back-Entry, 2-Pin JST SH-Style Connector Board and cable (cable not included). |
|---|
 |
| Micro Metal Gearmotor with Side-Entry, 2-Pin JST SH-Style Connector Board and cable (cable not include). |
|---|
- Motor controllers and drivers: We have a number of motor controllers and motor drivers that can be used to control these Micro Metal Gearmotors. In particular, the MP6550 motor driver is well suited for these motors, as are our Motoron M1x550, M2x550, M3S550, and M3H550 chainable serial motor controllers.
 |
| MP6550 Single Brushed DC Motor Driver Carrier. |
|---|
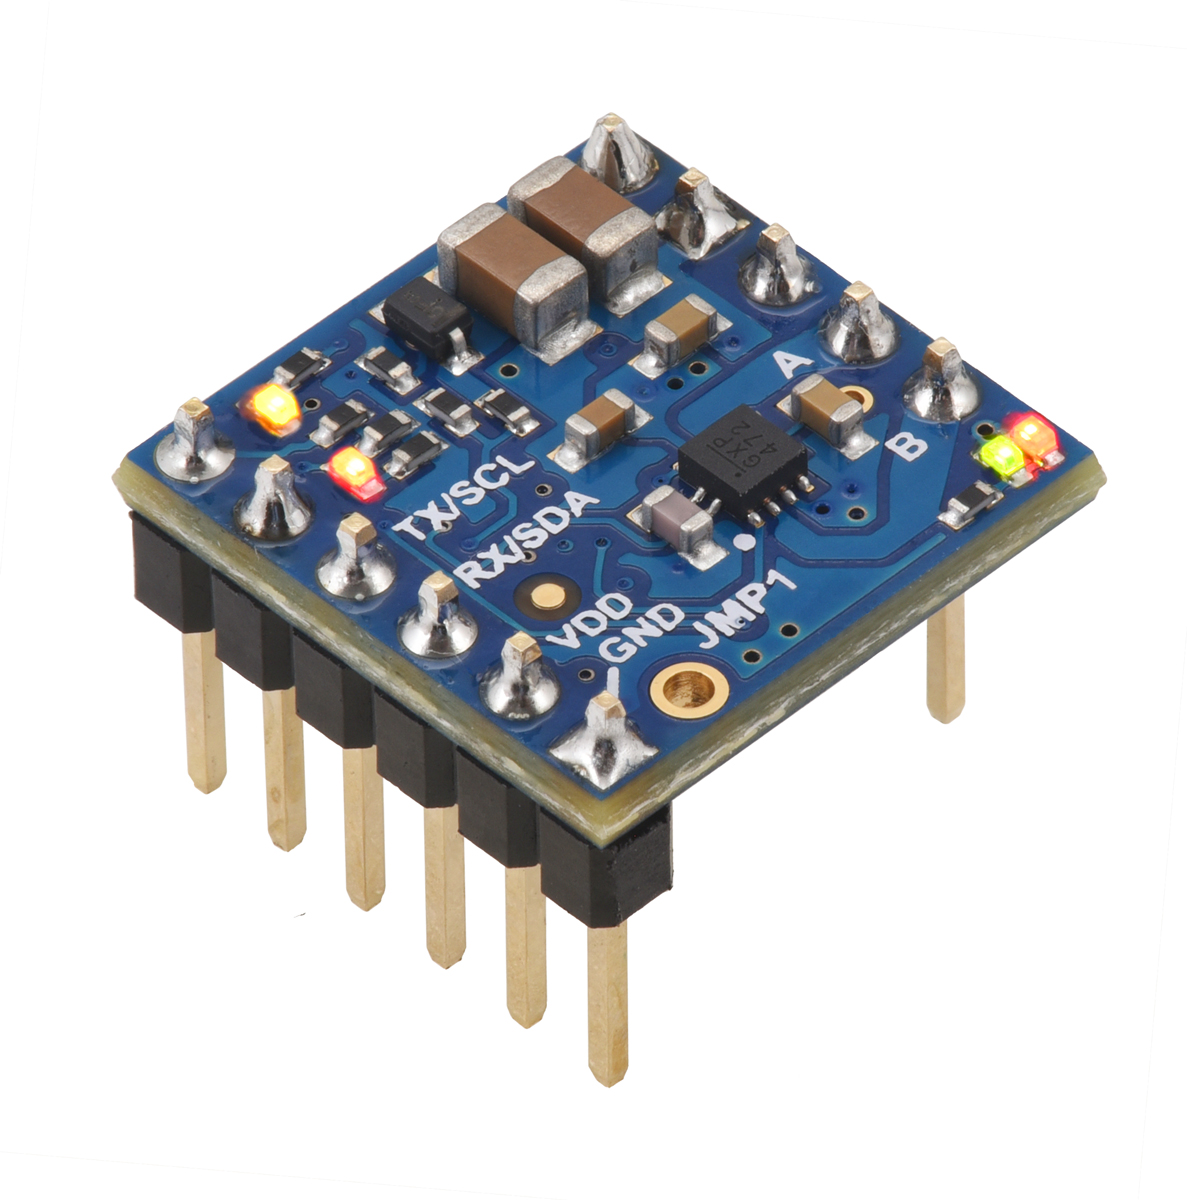 |
| Motoron M1T550/M1U550 Single Motor Controller (Header Pins Soldered). |
|---|
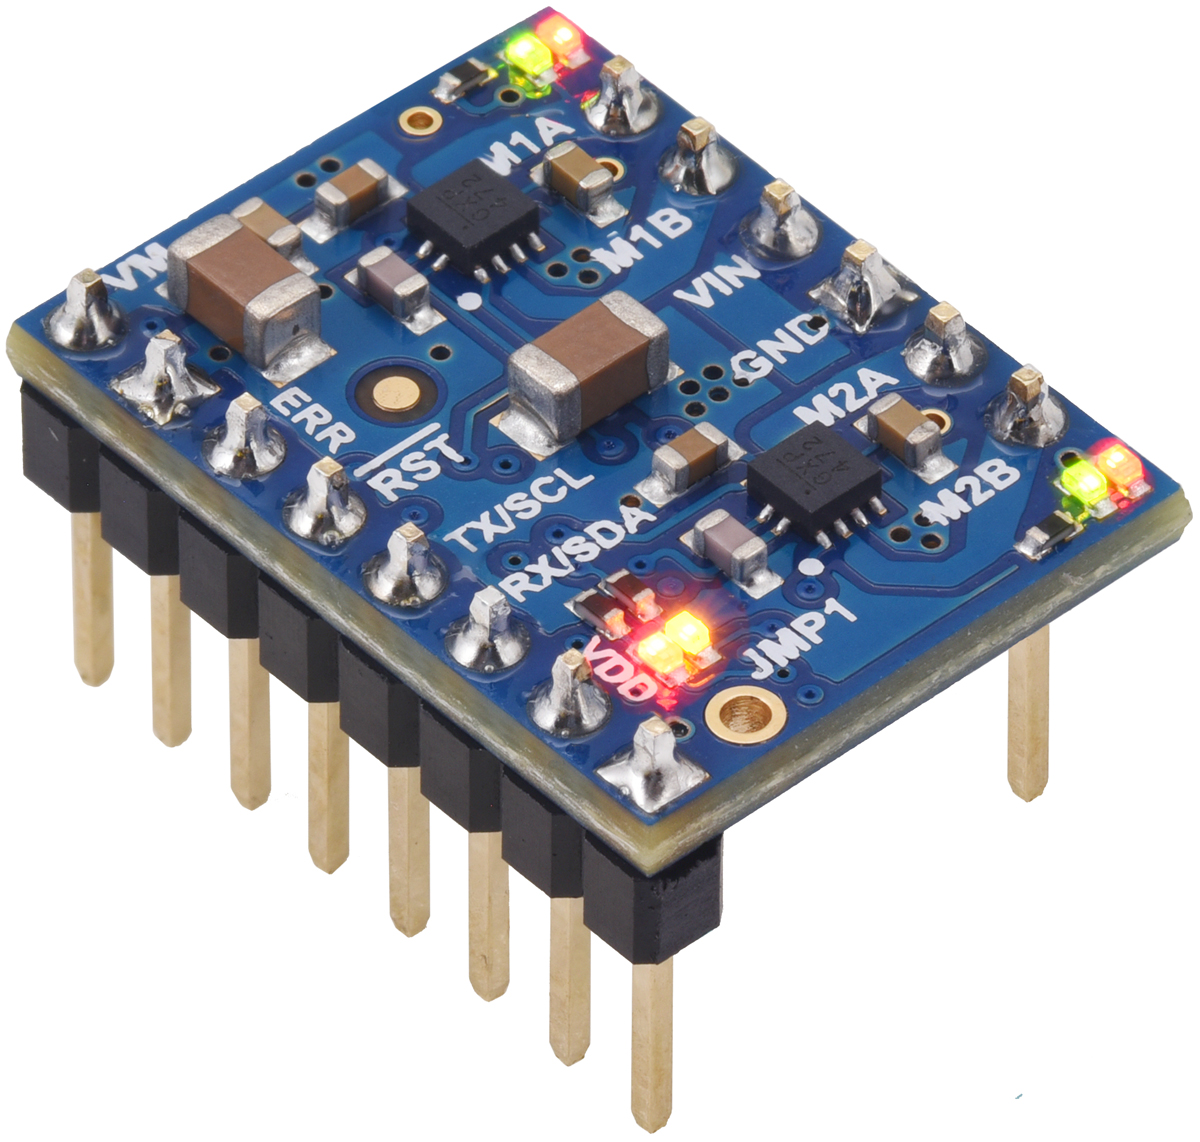 |
| Motoron M2T550/M2U550 Dual Motor Controller (Header Pins Soldered). |
|---|
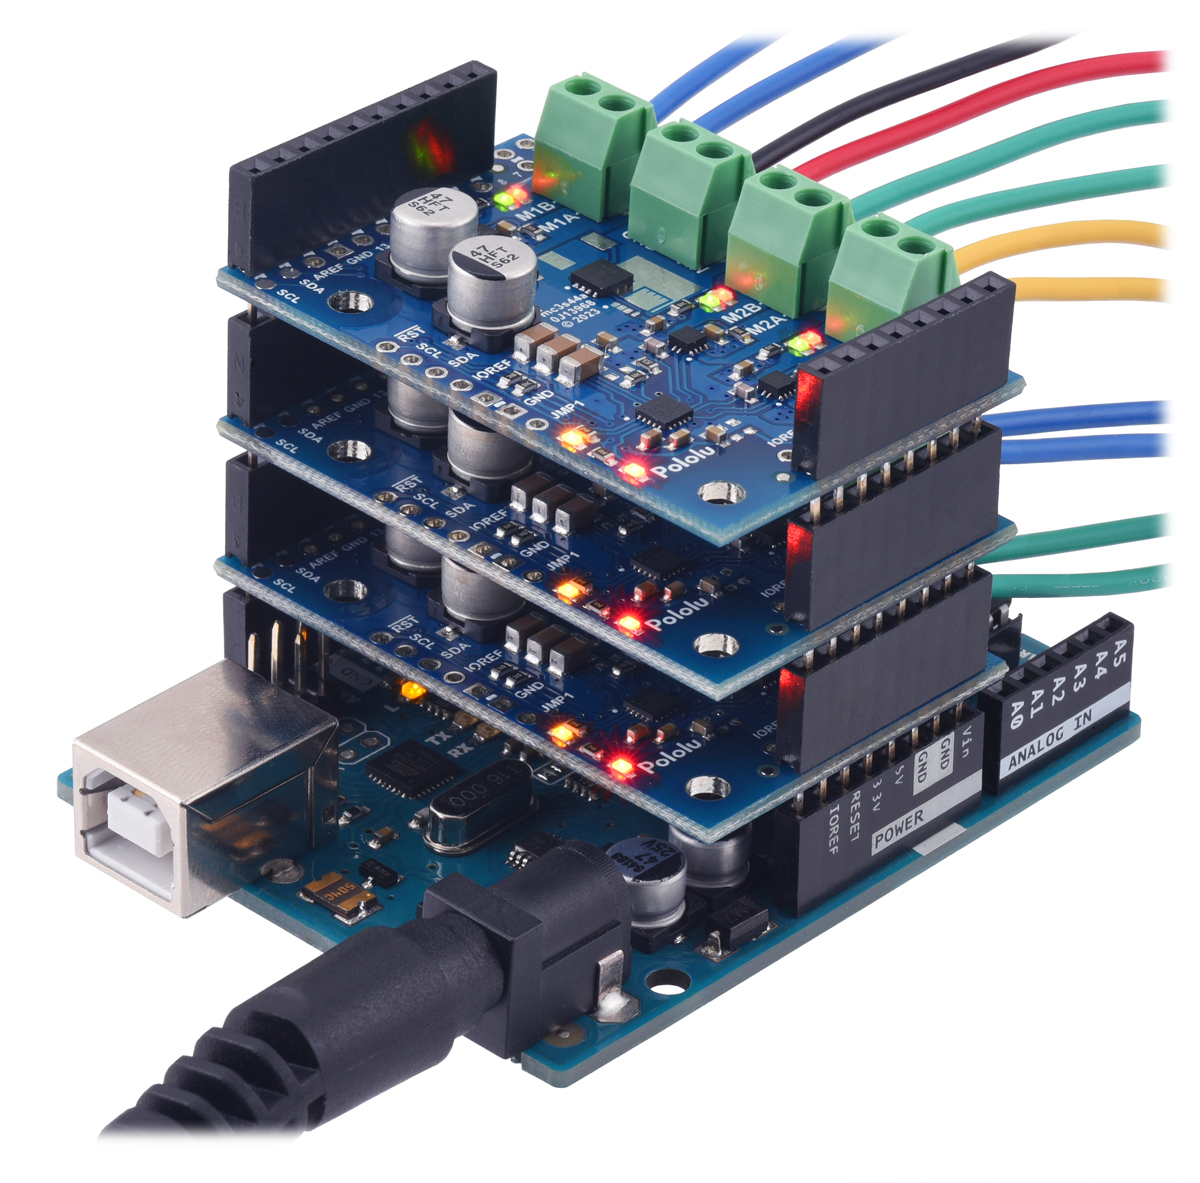 |
| Three Motoron M3S550 shields being controlled by an Arduino Uno. |
|---|
- Current sensors: The recommended motor control options above have built-in current sensing, but we also have an assortment of stand-alone Hall effect-based current sensors to choose from:
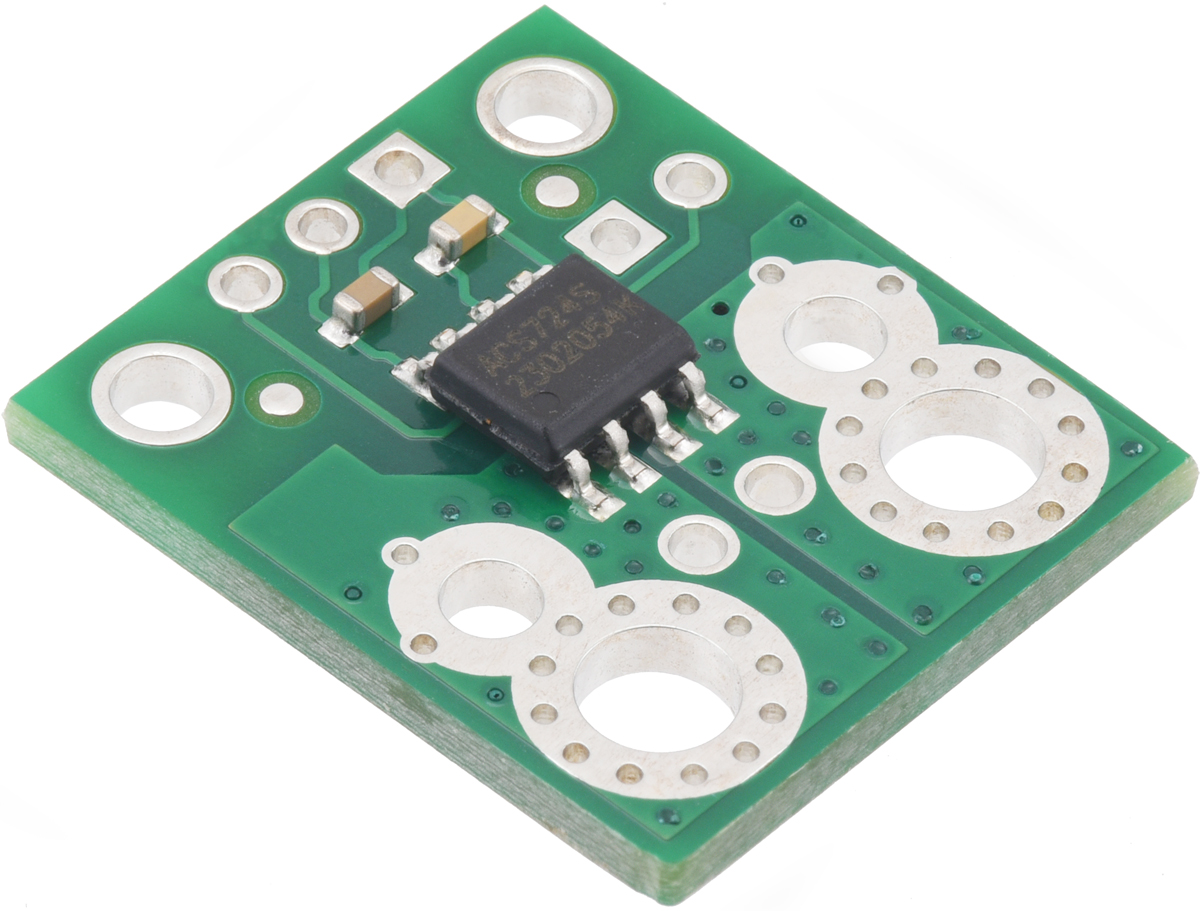 |
| ACS724LLCTR-2P5AB Current Sensor Carrier -2.5A to +2.5A. |
|---|
We also incorporate these motors into some of our products, including our Zumo robot and 3pi robot :
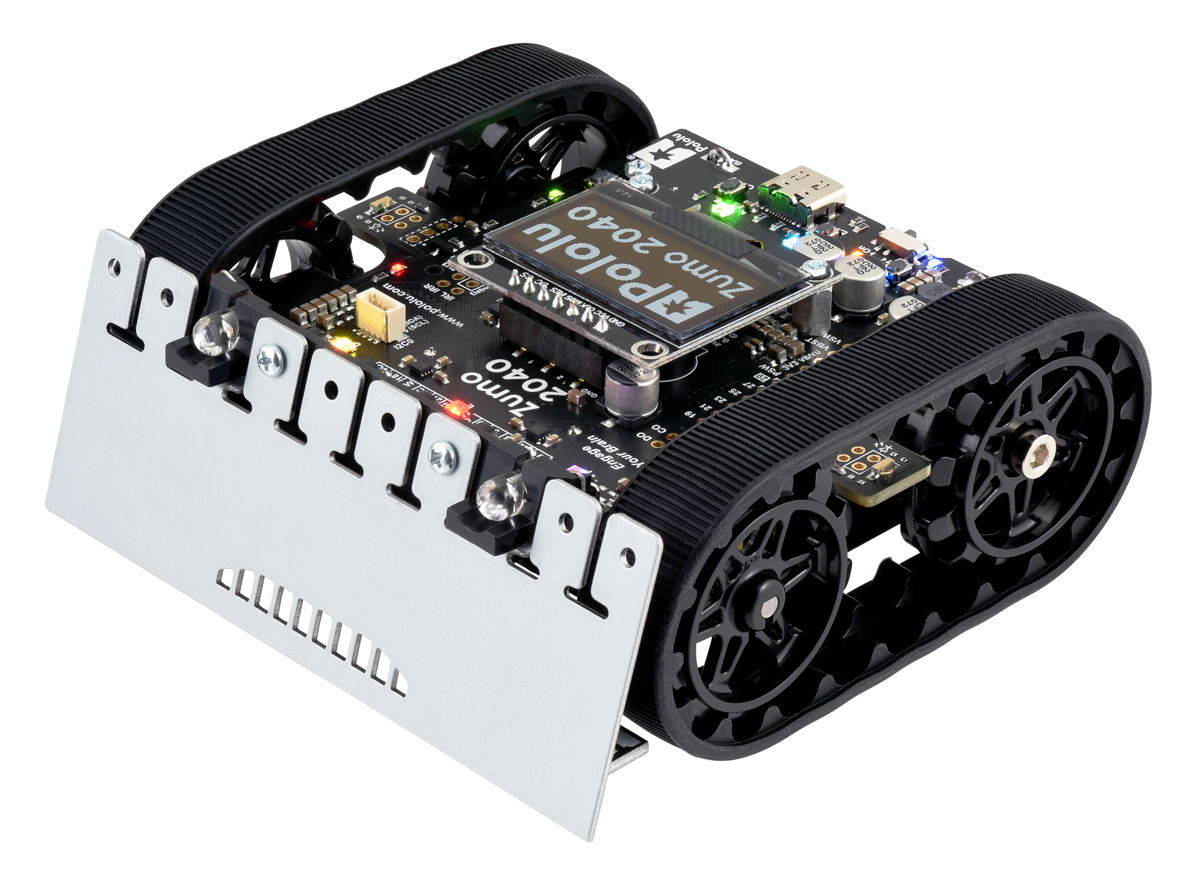 |
| Assembled Zumo 2040 robot. |
|---|
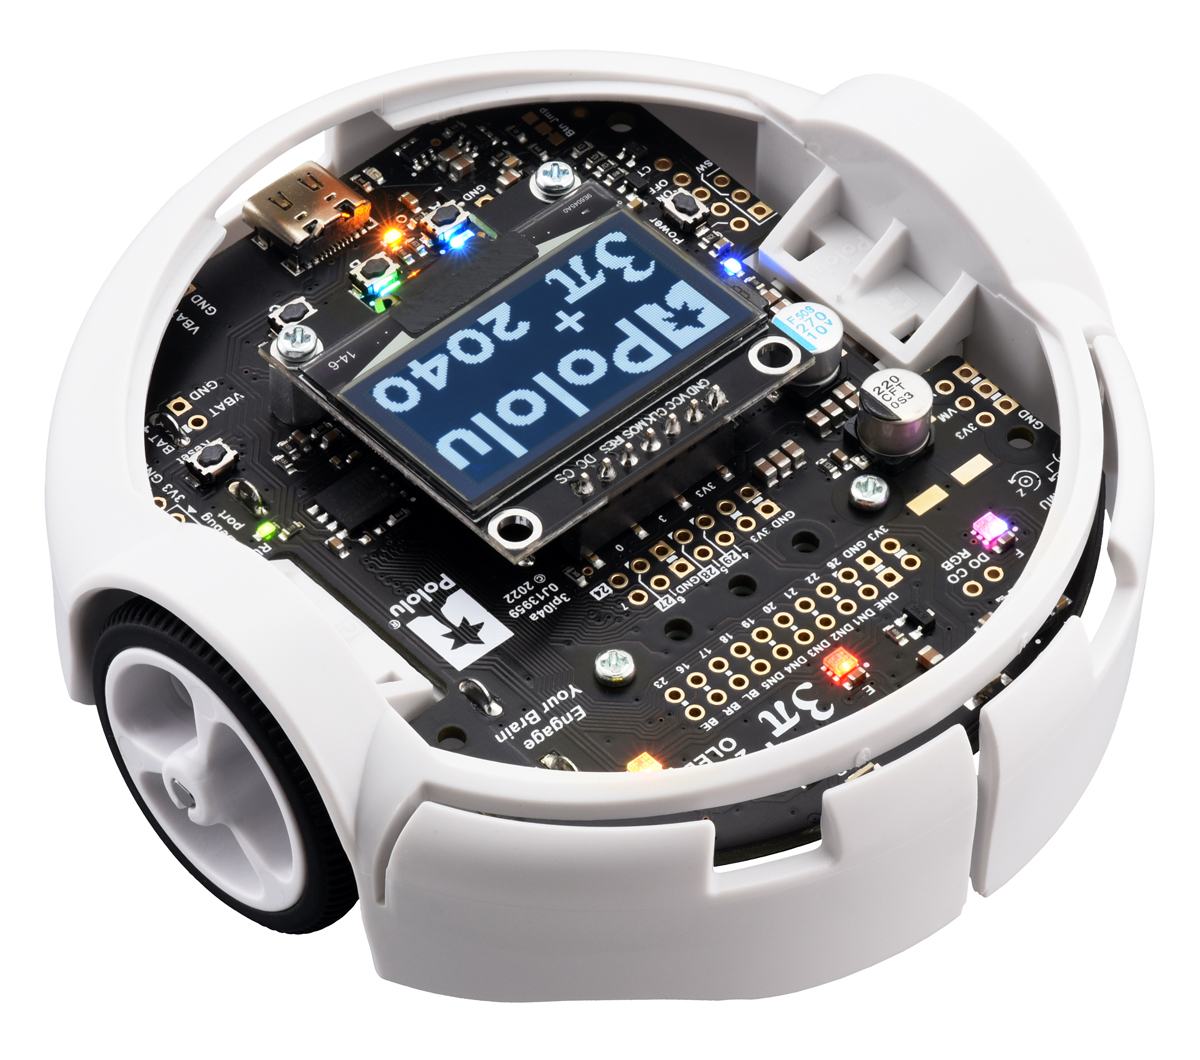 |
| 3pi+ 2040 Robot. |
|---|


